RoboMirage
High-Precision General-Purpose Physics Simulation Platform
A Scalable Contact Modeling Framework Compatible with All Object Types
Supports diverse contacts among rigid bodies, 1D/2D/3D deformable bodies, multi-joint structures, and various robotic end-effectors, with strong coupling simulation capabilities. It is compatible with future differentiable simulation and high-precision training needs, and allows user-defined extensions, providing a flexible underlying architecture for diverse scenarios.
High-Precision Multibody Dynamics Simulation
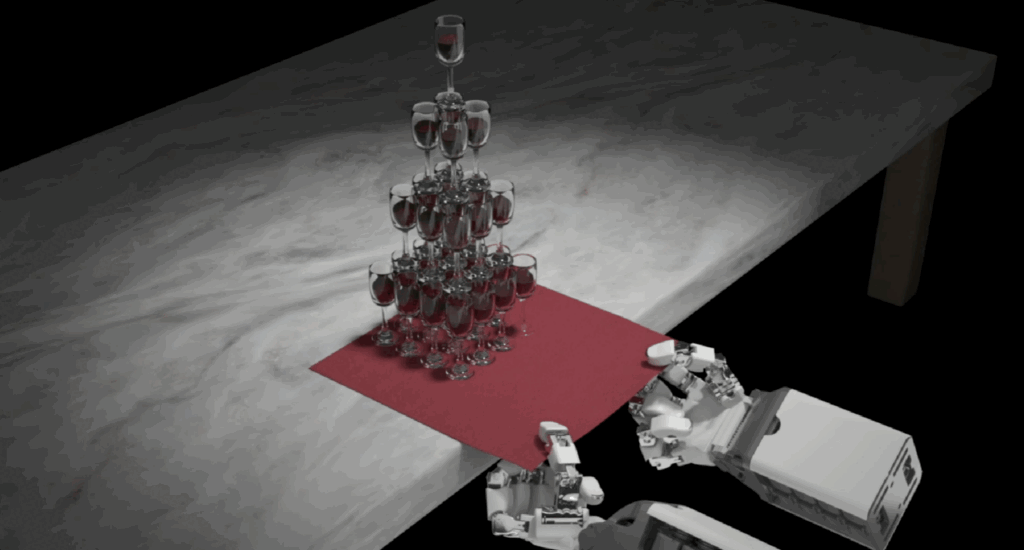
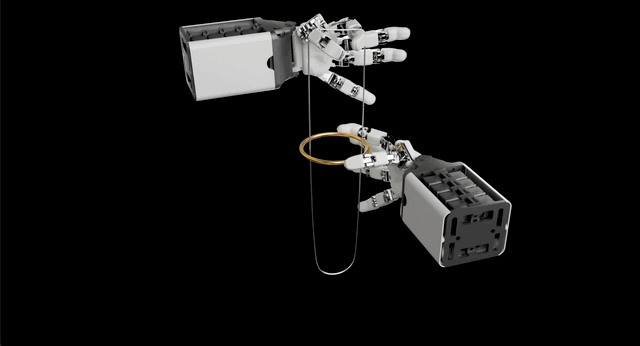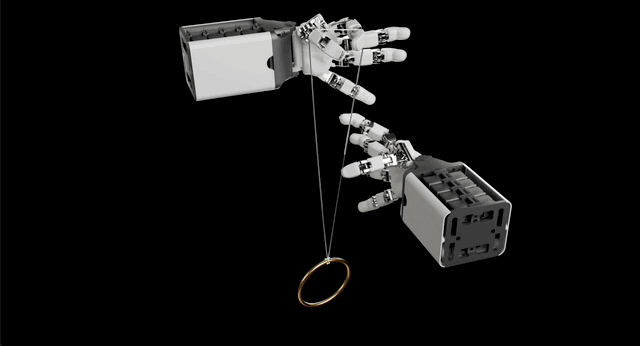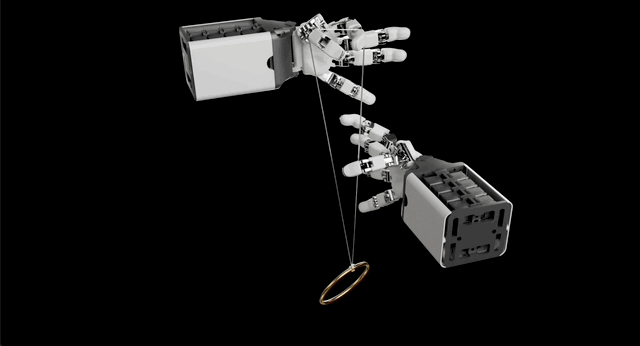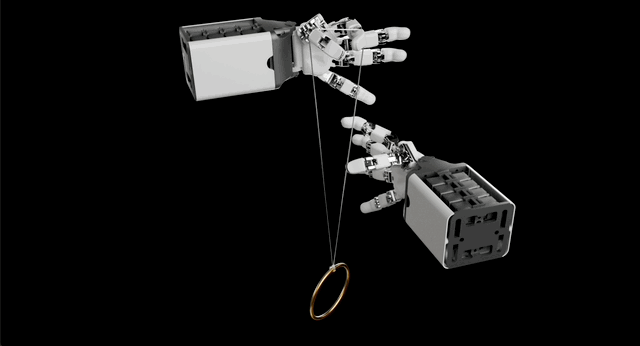
High-precision, non-penetrating, and time-consistent contact force simulation, supporting strongly coupled dynamics of rigid bodies, soft bodies, and complex contacts (e.g., strongly coupled interaction between complex cloth and robotic end-effectors). It captures microscopic dynamic details such as static/dynamic friction and subtle force variations. Its accuracy far exceeds traditional dynamics simulators, making it especially suitable for complex simulation needs in robotics.
Industrial-Grade Stable Algorithms
Based on rigorous mathematical theories such as implicit integration and convex optimization, it accurately solves continuum mechanics problems, ensuring simulation stability and time consistency at the algorithmic level. It captures every dynamic detail and completely eliminates penetration/tunneling issues. It meets the stringent simulation reliability requirements of industrial tasks such as assembly and grasping, providing continuous and stable operation for complex scenarios.
Pythonic Design, Simple and Easy to Use
The framework is designed with user experience in mind, featuring friendly interfaces that are easy to learn, enabling developers to quickly integrate and customize for efficient simulation development.
Advanced GPU-Driven Heterogeneous Acceleration
Fully leverages GPU massively parallel computing power combined with data-oriented programming to achieve high-performance, high-speed simulation at industrial-grade accuracy, significantly outperforming traditional finite element analysis and existing robot simulation platforms.