Category: Uncategorized
-
General Manipulation Model — Introducing the VLOA Large Model (Part 2)
General Manipulation Model Linking World Models to Action: Transforming Dynamic 3D Point Clouds into Precise Physics-Based Actions Across Embodiments. If a robot can “rehearse” the future, how should it turn its imagination into reality? This is precisely the central question that the “General Manipulation Model” within RoboScience’s VLOA large-scale model seeks to address. In the…
-
Embodied World Model — Introducing the VLOA Large Model (Part 1)
Embodied World Model Unlocking the Black Box of Physical Cognition with Object 3D Point Cloud Trajectories If a robot could “rehearse” the future before taking action—anticipating what contacts will occur, how objects will move, and whether its trajectories are feasible—would it become smarter? This is precisely the question that RoboScience’s “Embodied World Model” seeks to…
-
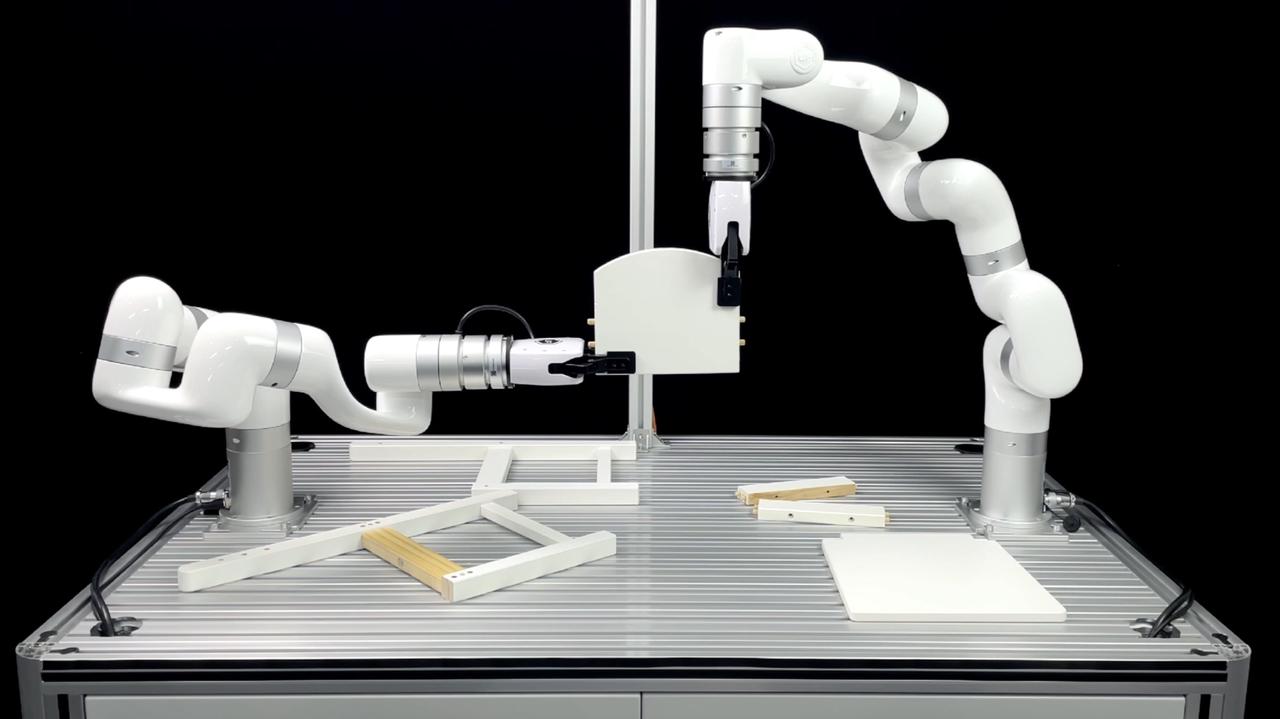
RoboScience has closed a pre-A round of financing worth several hundred million yuan, with its VLOA—integrating embodied world models and large-scale embodied manipulation models—driving the scalable deployment of embodied intelligence.
RoboScience has completed a pre‑A round of financing totaling several hundred million yuan. The round was led by Puhua Capital, with participation from Dacheng Capital, Changshi Capital, Hong Kong WiseTech Innovation, and Tianqi Capital. Existing investors, including China Merchants Capital and 01 Venture Capital, also increased their stakes. Huaxing Capital served as the exclusive financial…
-
RoboScience has released RoboMirage, enabling high-precision unified simulation of contact forces among rigid bodies, soft bodies, and articulated systems.
In the development trajectory of embodied intelligence, securing vast quantities of high-quality data remains a central challenge that the industry cannot sidestep. If large language models rely on internet-scale corpora, then the development of embodied intelligence likewise requires large‑scale interactive experience. In practice, collecting such data is extremely costly. Hardware such as robotic arms is…